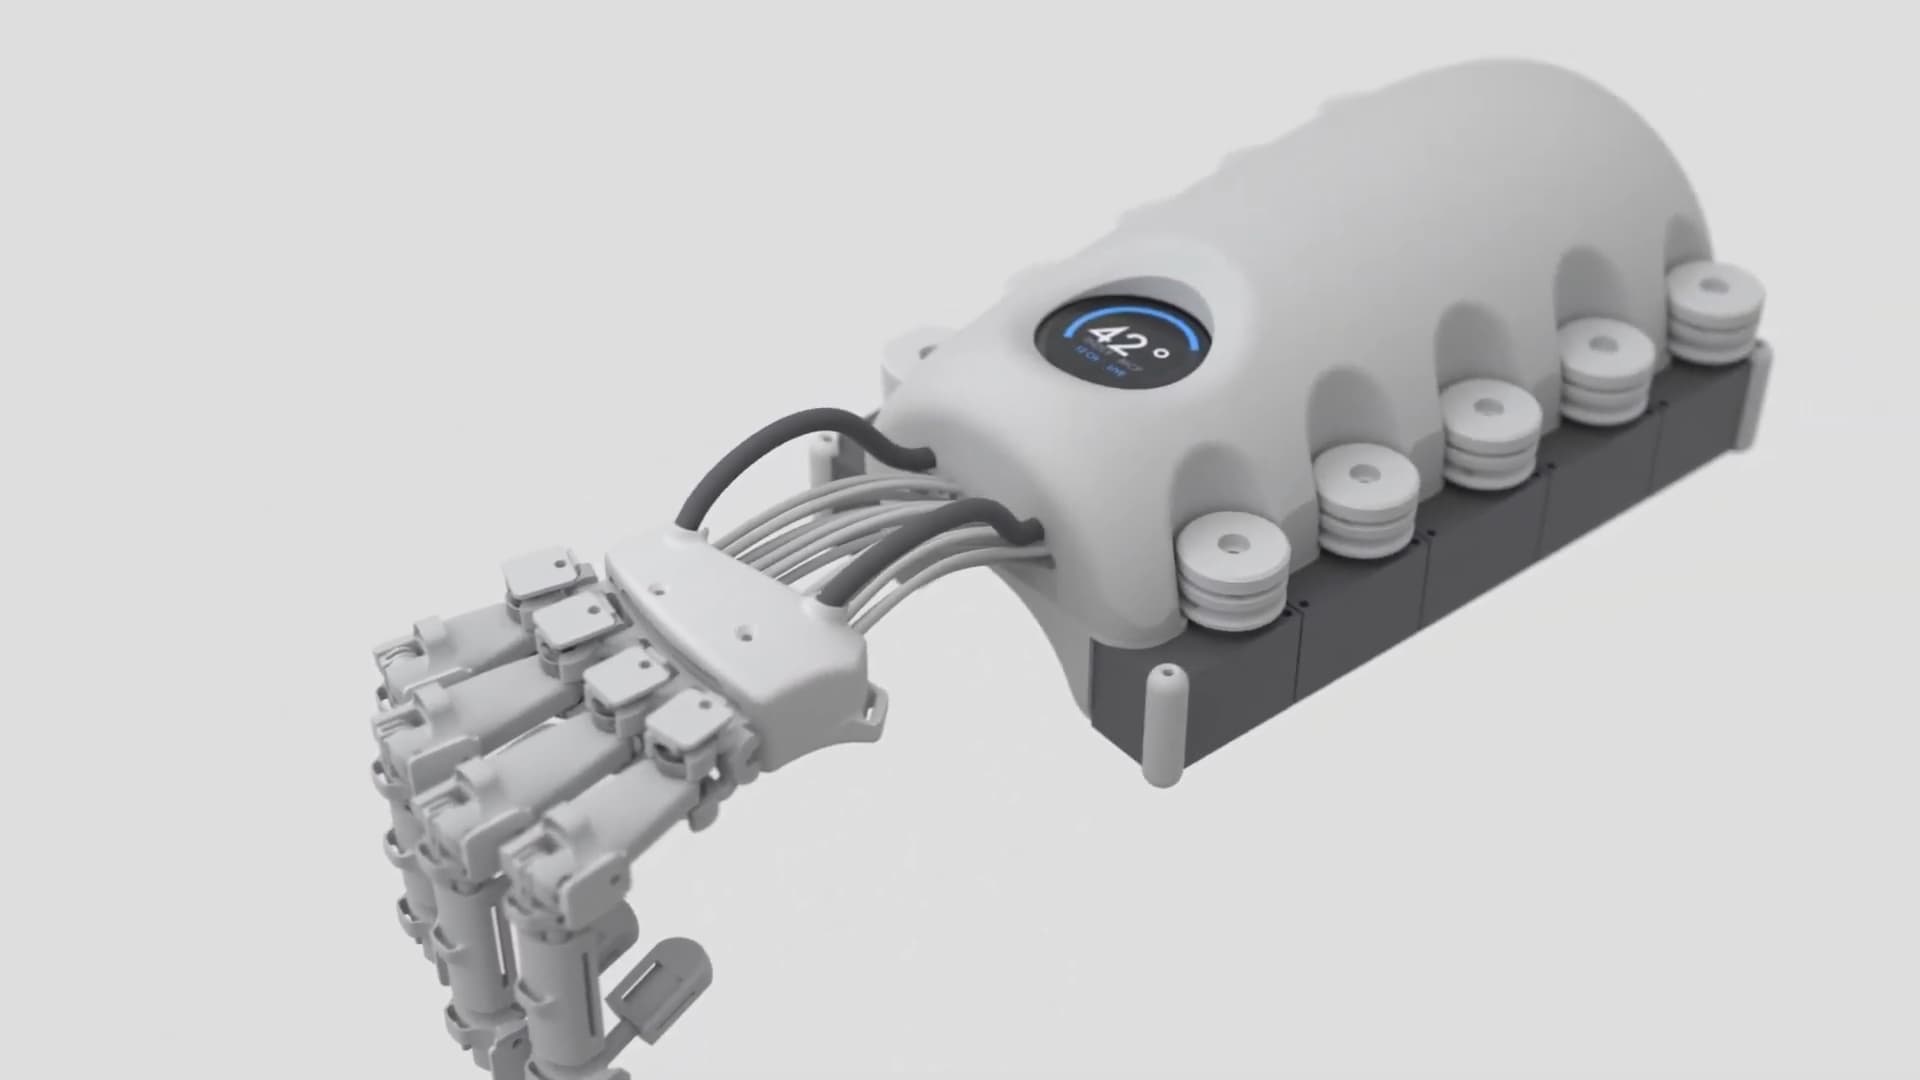
Sebastian Molano built TAKTO, an open-source hand-tracking exoskeleton glove, as his graduate thesis. It ditches camera-based tracking entirely, using magnetic encoders to report finger position and actuators to deliver physical feedback directly to the fingers. The full design, firmware, and assembly docs live on GitHub at molanocortes/takto-one.
The ecosystem is what separates TAKTO from prior one-off glove projects. TAKTO.one hosts a live digital twin console that mirrors the physical glove's state in real time, plus step-by-step visual assembly guides. There are two hardware tiers: a sensing-only version for basic hand tracking, and a fully actuated version at a significantly higher price point driven by the cost of quality actuators.
Read the full piece for the specific encoder and actuator choices Molano made and why, the tradeoffs between the two hardware configurations, and how TAKTO's architecture could slot into existing VR setups alongside recently released Valve hardware CAD references.
[READ ORIGINAL →]