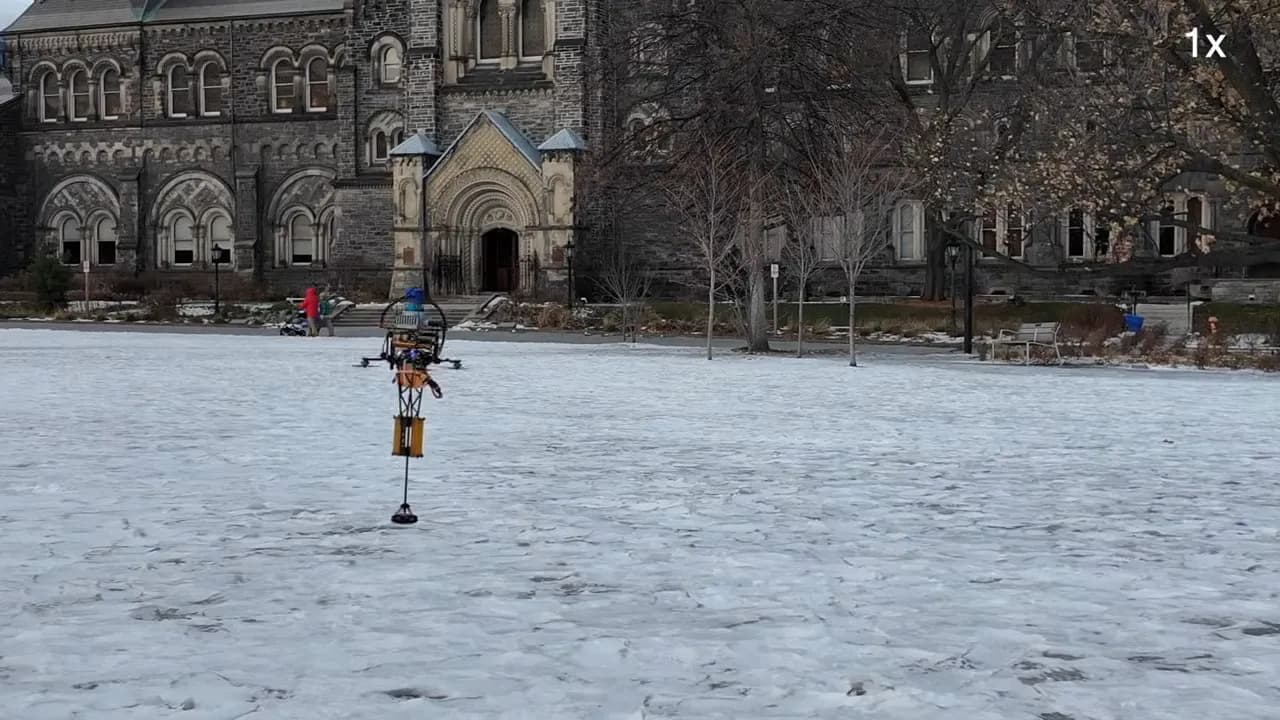
University of Toronto engineering students built a monopedal hopping robot that combines quadcopter thrust with a spring-loaded single leg to traverse soft sand, hard ice, and everything between.
The propellers provide lift energy, but all hopping mechanics come from the compliant leg alone. Early versions used a bare spike for ground contact and failed in ways the video documents without mercy. The fix: a pivoting footpad with traction material and elastic tensioning, letting the foot conform to uneven terrain instead of deflecting off it. That change is the difference between a robot that hops fences and one that spins out on a patch of ice.
One-legged robots exist in several forms, from leg-only designs to winged pogo bots, but this is the first documented example operating in Canadian winter conditions. The full video shows the progression from failed spike to compliant foot and is worth watching for the failure modes alone.
[READ ORIGINAL →]