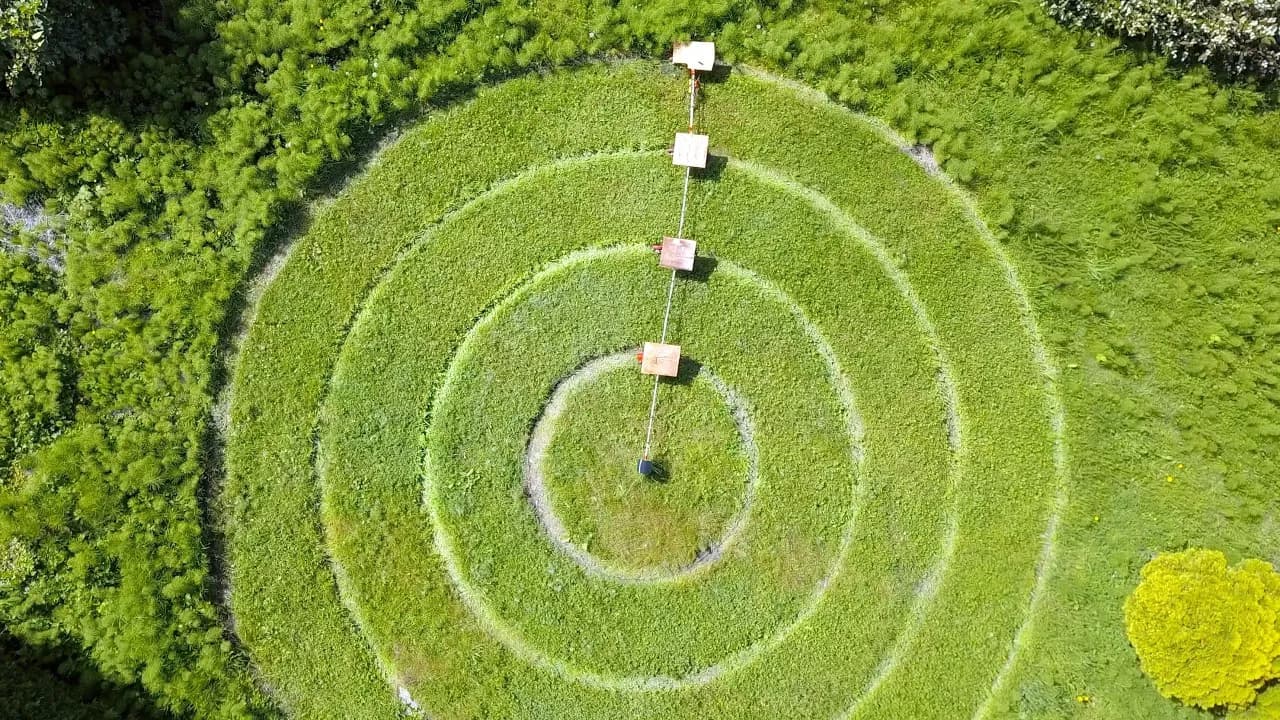
[rctestflight] built a miniature center-pivot irrigation system that mows his lawn in circles. The machine replicates the same control logic used by the massive agricultural systems visible from aircraft over the US and Australia: semi-independent sections, flexibly coupled, driven by coordinated wheel assemblies.
The engineering details are what make this worth reading in full. The first control scheme used limit switches at each interior coupling to trigger inner wheel sets once the outer wheels passed a setpoint. That was replaced with a potentiometer-based proportional controller. The mower attachment itself uses two pivoting precision knives mounted on motors, riding a carriage on one of the linkages, with limit switches keeping the carriage traversing back and forth across the cut zone.
Pacific Northwest conditions stress-tested the build hard: mud disrupted wheel traction, rapid plant growth blocked the robot's path, and moisture caused corrosion across multiple components. The circular test area already existed from prior RC car durability experiments, which cut one step from setup. The full video documents each failure mode and fix, making it a practical reference for anyone building terrain-navigating autonomous ground vehicles.
[READ ORIGINAL →]